GenPHRI

Agentic Generative Simulation
for Physical Human-Robot Interaction

Junxiang Wang*Nir Pechuk*Xinwen Xu*Tiancheng Wu†Nayon Kim†Julian MillanZackory Erickson

Robotics Institute, Carnegie Mellon University

* Equal contribution   † Equal contribution

From task prompt to real world execution.

Physical human-robot interaction is hard to author by hand. GenPHRI turns natural-language task descriptions into complete simulated scenarios: a human, a setting, a robot, and the motion that connects them.

Real-world deployment

Generated motion can be deployed directly for a rapid physical preview, or used to train a vision policy for closed-loop interaction. Both routes start with the same scenario.

Direct Execution

Fit a human body mesh from a single image, then evaluate the generated motion on that body. No demonstration collection or policy training.

A fast way to inspect the intended behavior. Contact coverage depends on the accuracy of the fitted body mesh.

4x speed

Policy Learning

Collect demonstrations across diverse simulated bodies and train a visuomotor policy that responds to observations throughout the interaction.

Higher contact coverage through closed-loop control. Trained entirely in simulation, with no real-world fine-tuning.

4x speed

Real-world target completion

In a 12-participant study, learned policies achieved 80% bathing and 79% scratching target completion without instructed arm movement.

Direct execution and policy learning had no statistically significant difference in bathing prompt-adherence ratings, while learned policies achieved substantially higher contact coverage.

Mean target completion with standard deviation across participants: bathing policy 80 ± 11 percent, bathing direct execution 39 ± 25 percent, scratching policy 79 ± 16 percent, and scratching policy with arm movement 63 ± 20 percent.
Completion measures targets removed or contacted in a 12-participant real world user study.
Watch six user-study trials
Bathing and scratching user-study trials.
How completion and prompt adherence were measured

Bathing used 15 evenly distributed removable targets across the back and legs; scratching used five contact markers along the forearm. Participants rated adherence to the original task prompt on a seven-point scale.

Each policy was trained on 1,000 simulated demonstrations across 100 human bodies. Simulated evaluation used 20 held-out bodies and two random seeds per body. Mean simulated completion was 86% for bathing and 92% for scratching. Simulated targets used a 2 cm proximity criterion, so the simulation and physical measurements are not identical.

Scratching with instructed arm movement reached 63% completion in real-world trials, highlighting a remaining challenge in adapting to human motion.

Scenario generation

Orchestrator Actions

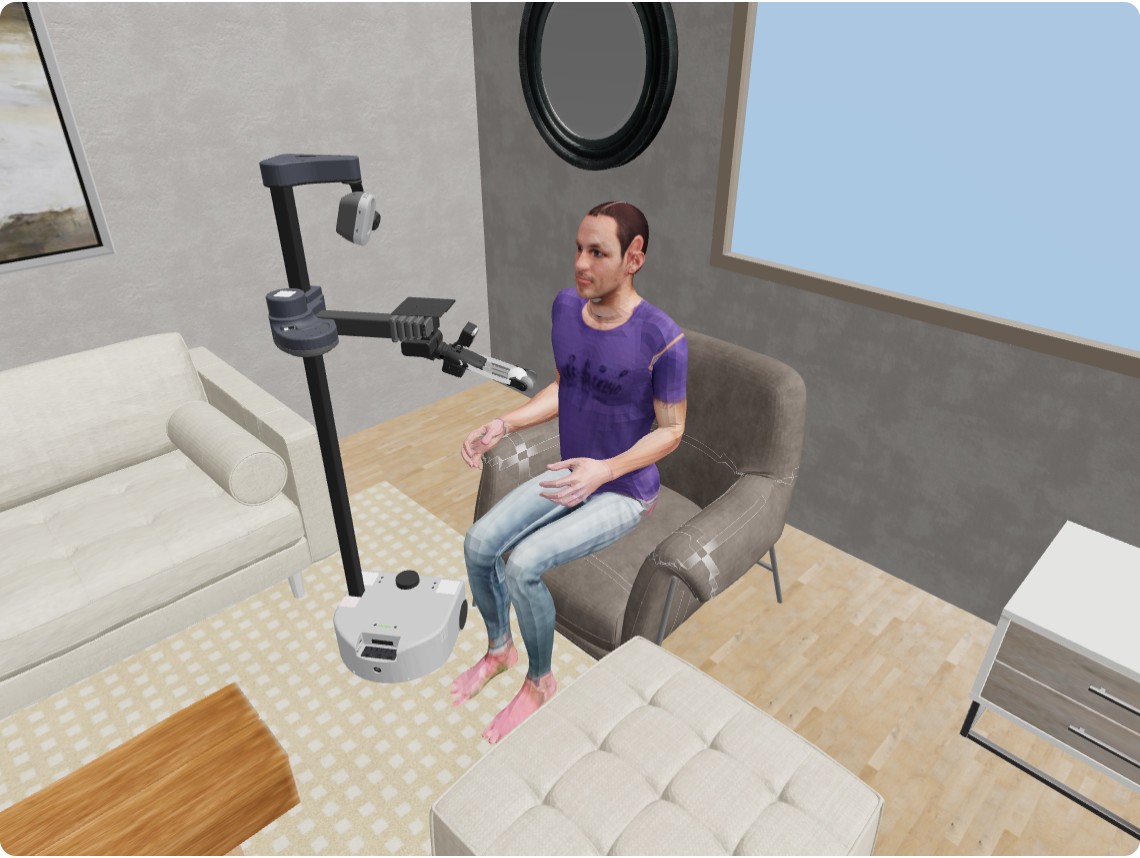
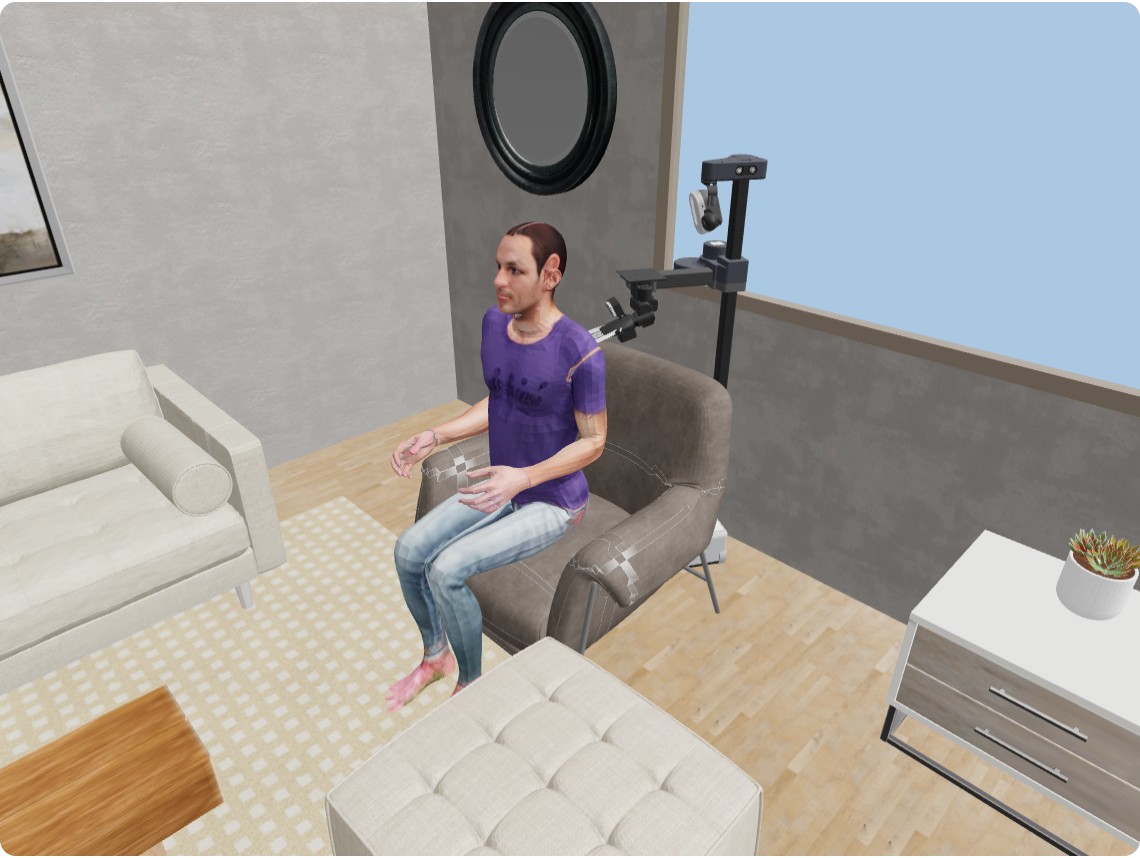
Task: Scalp Scratching

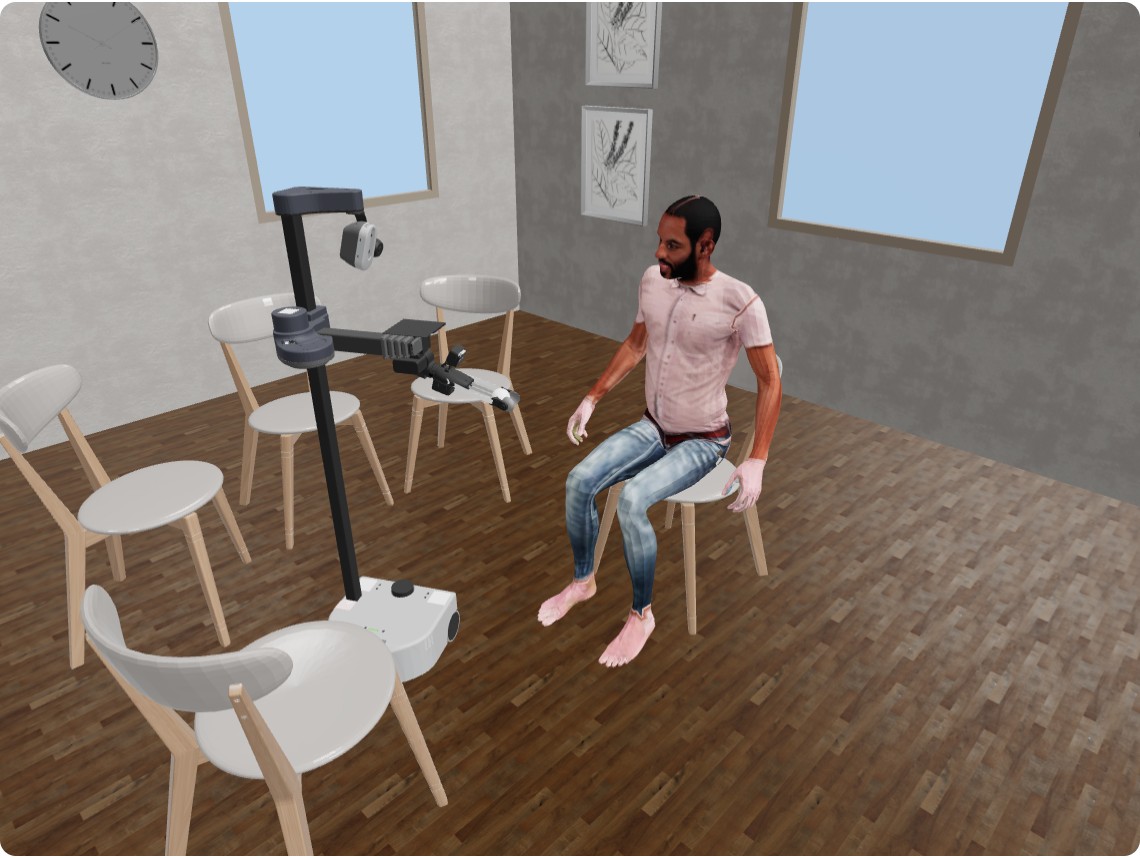
BeforeToo far from the scalp
Last candidate: robot beside the knees, failing scalp reachabilityLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
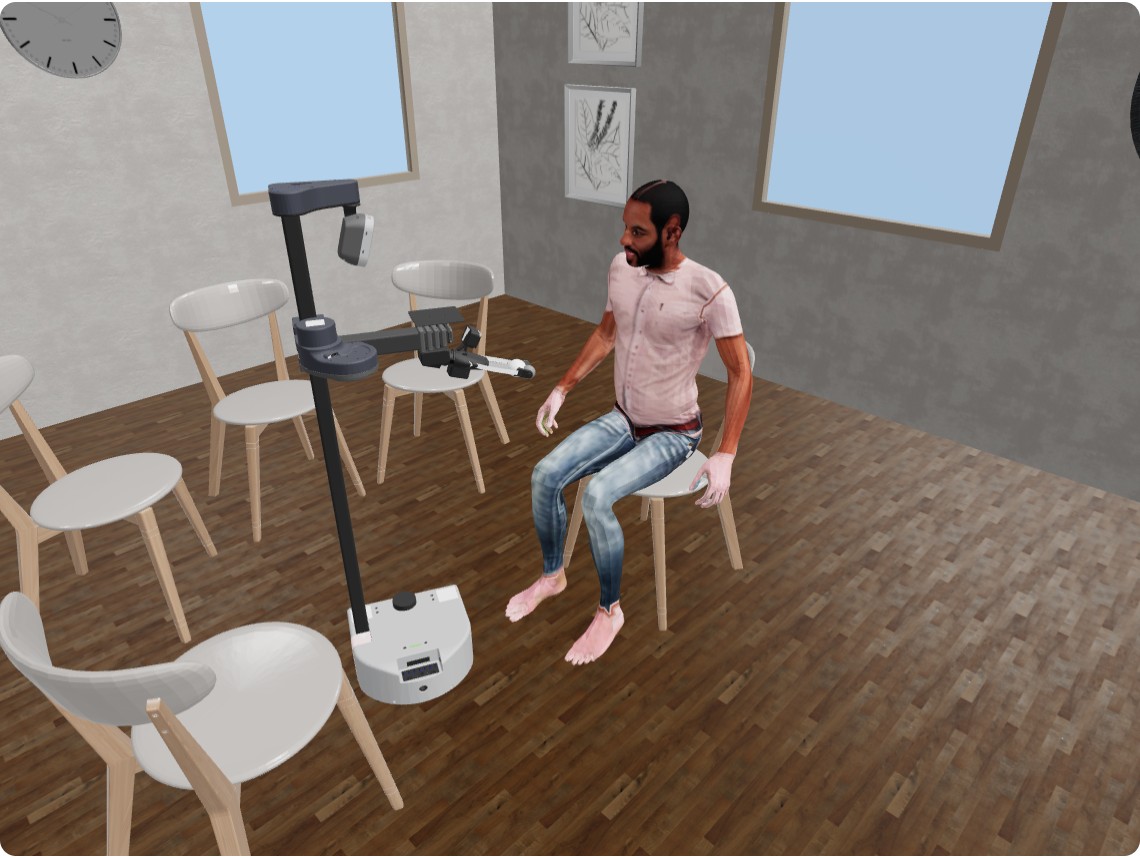
AfterEarlier best accepted
Accepted earlier candidate: robot behind the chair, closer to the scalp and passing reachability and clearance gatesLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
Orchestrator Excerpt

Attempts are exhausted. Accept the earlier placement that passes reachability and clearance checks, despite its less-preferred approach from behind.

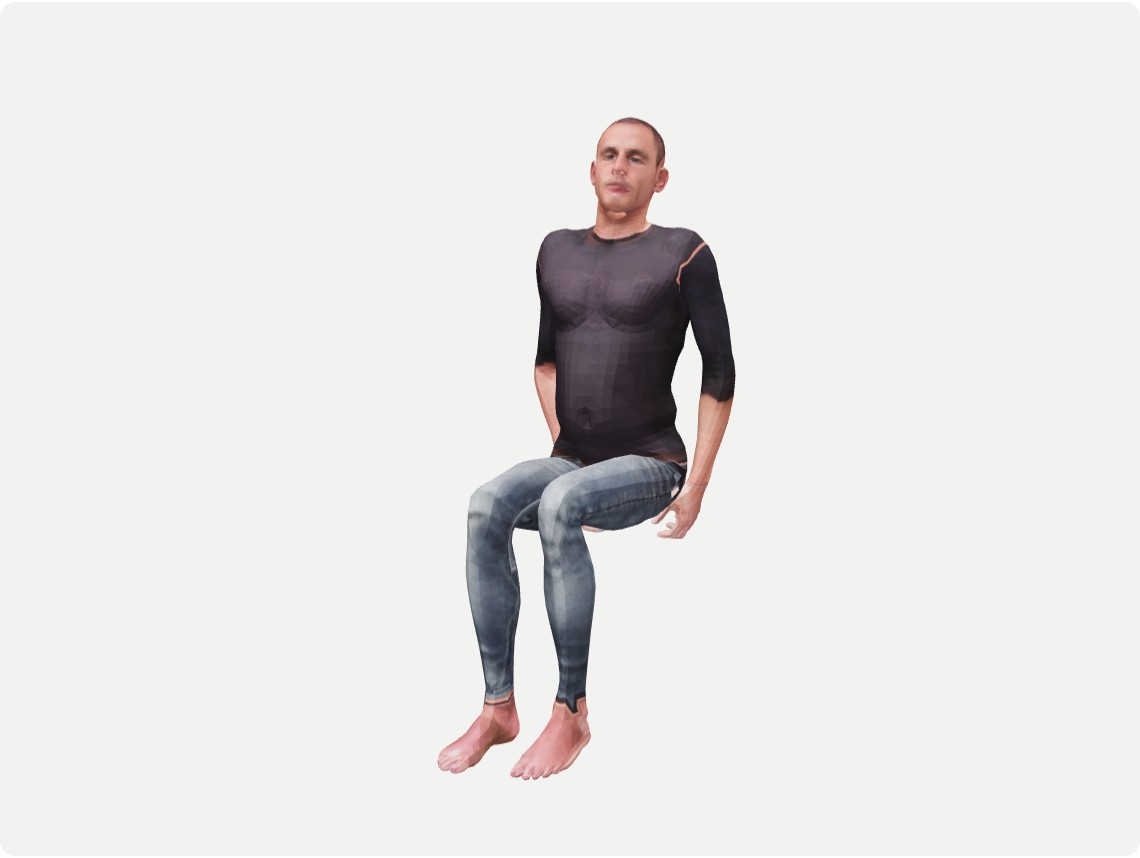
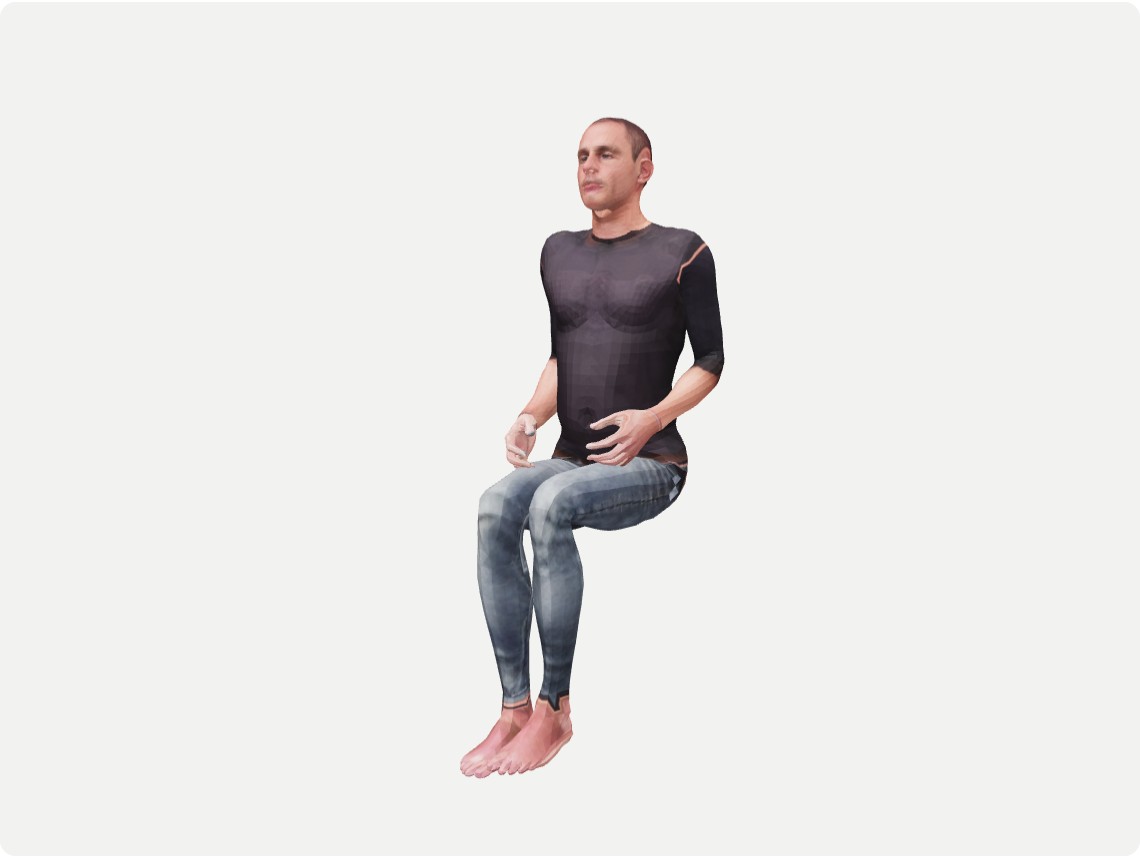
Task: Head and Neck Towel Drying

BeforeWrong arm position
Rejected pose with arms hanging behind the hips instead of forward over the lapLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
AfterPose accepted
Accepted pose after the contextual retry, with elbows bent and hands forward over the lapLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
Orchestrator Excerpt

The hands remain beside the hips across repeated attempts. Retry with explicit guidance to bend the elbows forward and bring the hands onto the lap.

Task: Right Foot Sponge Bathing

BeforeNeeds refinement
Before resume: needs refinementLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
AfterProper angle
After resume: robot placed at the revised angle toward the right footLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
Orchestrator Excerpt

The last candidate improved, but reach remains limited. Continue refinement with guidance to move closer to the foot.

Task: Mid-Back Percussion

BeforeTarget unreachable
Before backtrack: target unreachableLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
AfterPlacement accepted
After backtrack: placement acceptedLoading scene…
Drag to rotate · Scroll to zoom · Right-drag to pan
Orchestrator Excerpt

The current human placement blocks access. Revisit it before trying robot placement again.

Full pipeline walkthrough

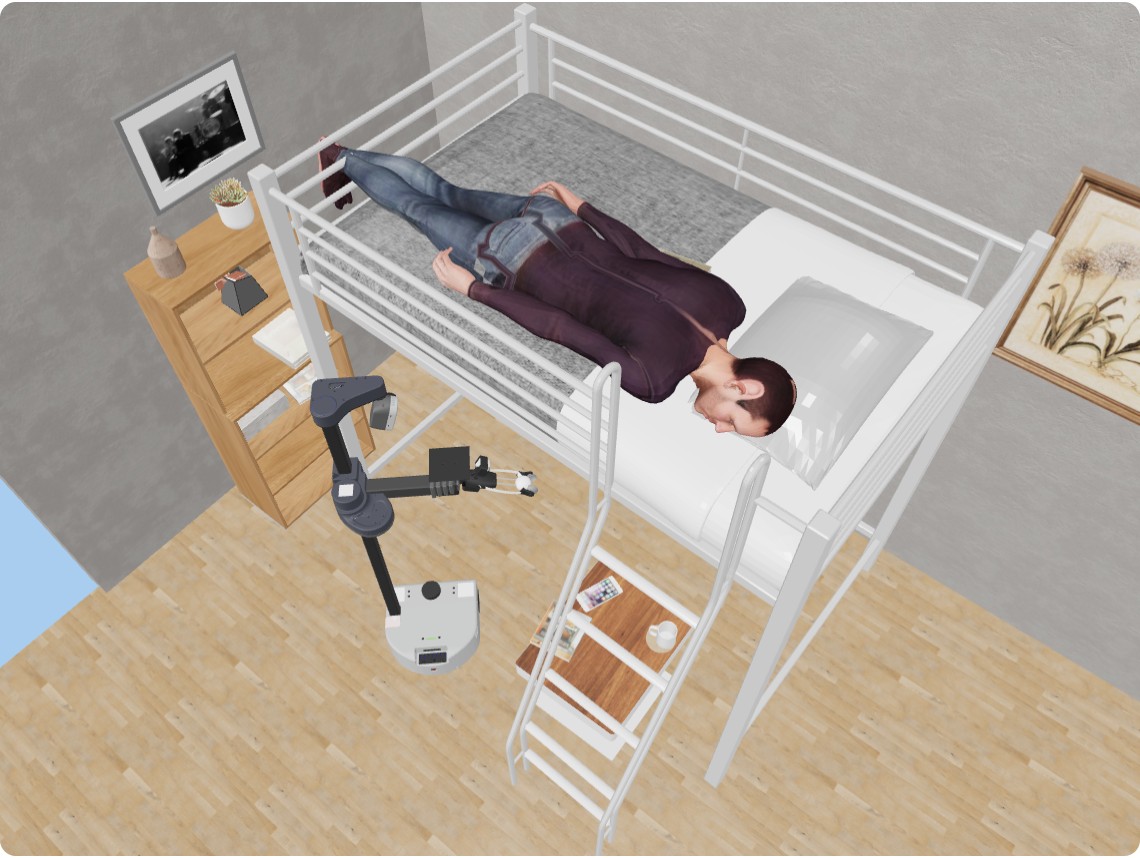
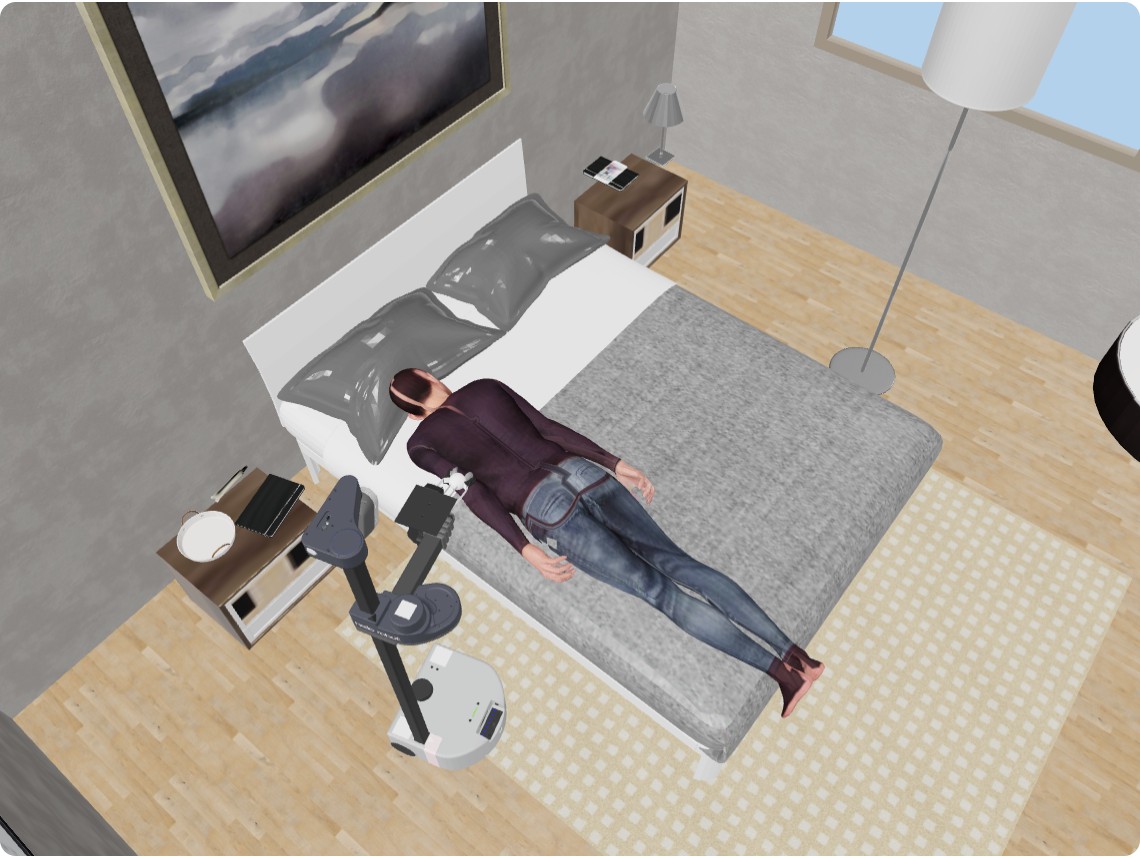
Task prompt: A person lies face-down on a bed, arms resting alongside the torso and legs extended straight. A robot bathes them with a sponge, wiping the whole back in several passes and then the back of each leg down to the ankle, and it pulls the sponge away from the body when it finishes. The robot must not touch the buttocks or the area between the legs.